How does ATO save train energy through coasting?
Lead Author
Published
Views:
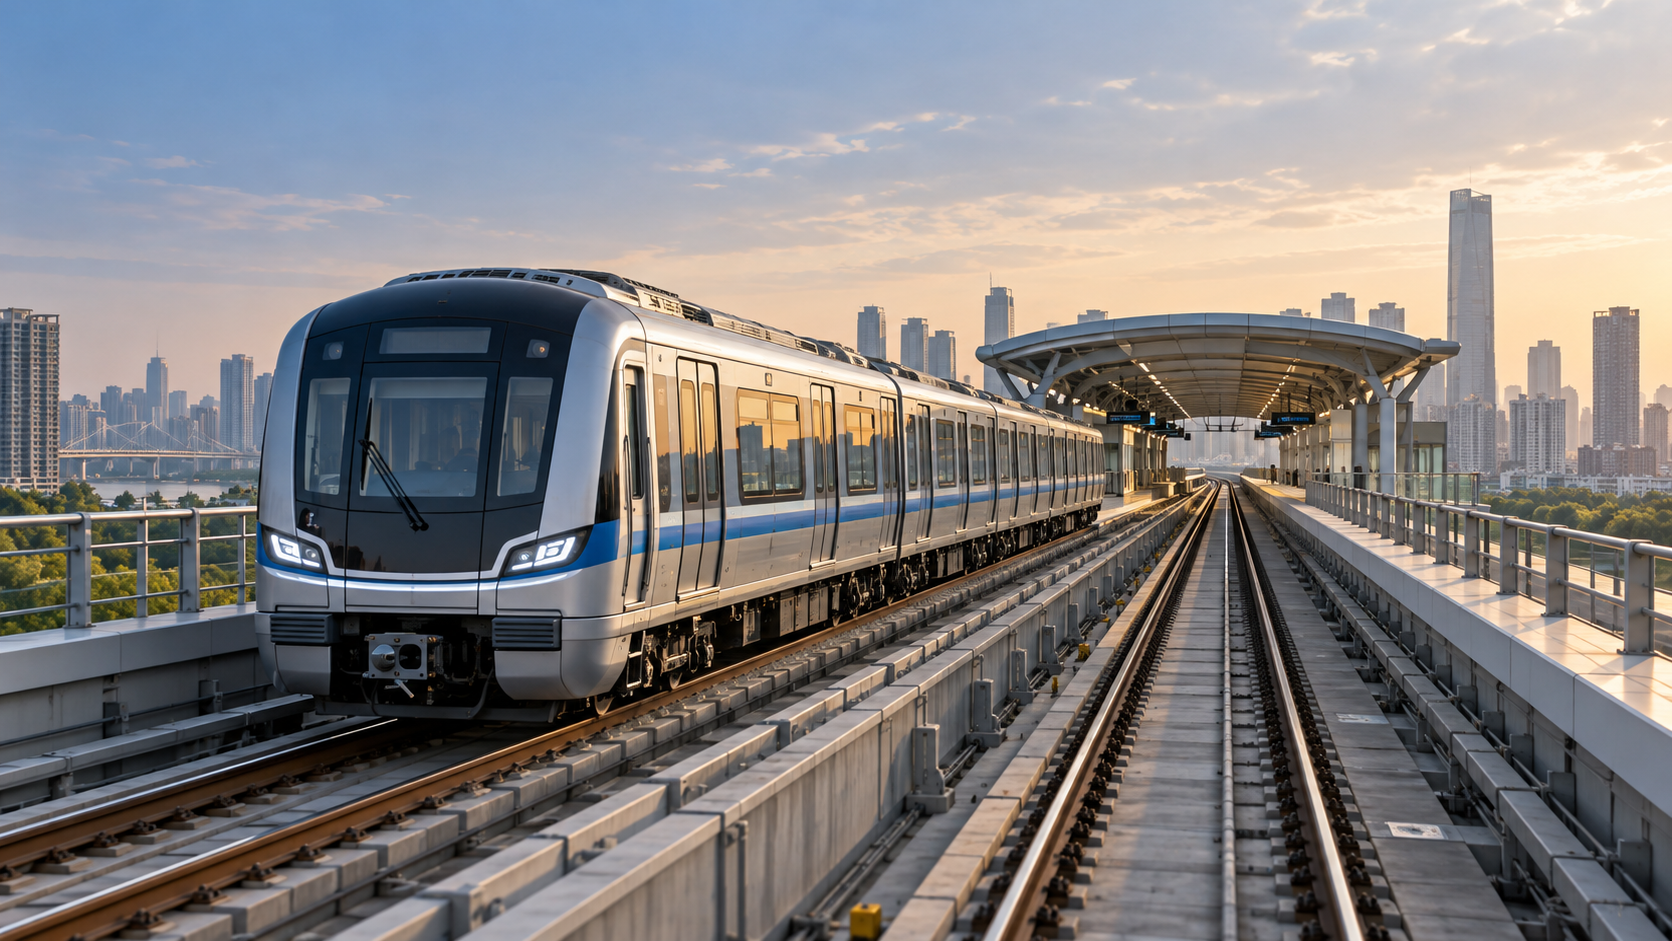
Automatic Train Operation (ATO) saves traction energy through coasting by switching off propulsion before a train reaches a planned braking point and allowing its momentum to carry it forward. The train slows naturally under running resistance and, where applicable, uphill gradients. By replacing part of a powered run and some subsequent braking with a controlled power-off phase, ATO can reduce the energy needed to complete a journey while still respecting the timetable and operating constraints.
The challenge is deciding where that phase should start and end. A train that coasts too early may arrive late or need to accelerate again; one that coasts too late may preserve punctuality but offer little energy benefit. Assessing ATO energy saving therefore requires more than counting coast commands: the speed profile, service conditions and electrical measurement boundary all affect the result.
Where the energy saving comes from
A typical station-to-station run includes acceleration, possibly a period at or near a permitted speed, coasting and braking. During coasting, traction power is set to zero or its effective minimum, although auxiliary equipment can continue to draw electricity. The train does not remain at a fixed speed: aerodynamic drag, rolling resistance, curves and gradients determine how quickly its speed changes.
Without an energy-aware coast phase, a controller may maintain speed until relatively close to a station and then brake to stop. Some energy used to sustain that speed must subsequently be removed by braking. An earlier power-off point can let natural resistance dissipate part of that energy instead, reducing the amount of traction energy supplied. The saving depends on the original driving profile; coasting is not automatically better than every alternative control strategy.
Regenerative braking complicates the comparison. When braking energy can be returned to the electrical network and used by another train, absorbed by storage or otherwise accepted by the supply system, some of the energy may be recovered. When the network cannot accept it, a greater share may be dissipated through braking resistors or other mechanisms. A coast-heavy profile can reduce both traction demand and regenerative output, so gross traction consumption alone does not establish the net system benefit.
A useful speed-distance plot shows the distinction: compare the powered, coast and braking portions of the ATO trajectory with those of a reference run, alongside speed limits and gradients. The most informative question is not simply whether the train coasted longer, but whether it avoided energy-intensive propulsion without causing compensating acceleration or an unacceptable journey-time penalty.
How ATO selects a coast point
An energy-oriented controller needs a model or an operational representation of the route and train. Depending on the implementation, it may calculate a trajectory in advance, update it during the journey, or select from prepared driving profiles. In each case, the intended outcome is a feasible sequence of traction, coast and braking commands rather than an isolated instruction to switch power off.
The calculation generally balances a journey-time target against energy use, subject to limits on speed, stopping position, acceleration and braking. A simplified sequence is:
- Establish the available running time. Use the departure state, target arrival time and operational margins to determine whether there is time to reduce speed before braking.
- Predict the train’s motion. Estimate how speed will change with traction off, using train resistance, mass, gradients and route restrictions.
- Choose a feasible transition. Identify a power-off point that keeps the train within speed limits and leaves sufficient distance for the required braking and stopping profile.
- Monitor and adapt. Update commands when actual speed, location or traffic conditions differ from the prediction, within the functions and interfaces provided by the system.
These are functional steps, not a prescription for a particular algorithm. Some systems optimize a full trajectory; others use rules or lookup tables. Evaluators should ask how each approach handles prediction error and changing movement authority, and whether an apparent saving relies on running times unavailable in normal service.
Timetable slack is usable, but not free
Coasting uses time that could otherwise be spent travelling faster. When scheduled running time exceeds the minimum feasible running time, the difference can create an opportunity to turn traction off earlier. However, that margin may also be needed to absorb dwell variation, temporary restrictions or other disturbances. Allocating all of it to energy optimization can make the service fragile.
Conversely, a delayed train may need a different profile to recover time. ATO can reduce or omit coasting when permitted and operationally appropriate. A meaningful assessment should therefore cover both stable operation and disrupted conditions, rather than assuming the same coast strategy is practical on every run.
Route and train conditions that change the result
Gradients can reverse the expected speed trend. On an uphill section, a train may decelerate quickly with traction off, potentially requiring power to be reapplied before the next target point. On a downhill section it may maintain speed or accelerate, making coasting attractive but also creating a risk of exceeding a speed restriction. The controller must predict the actual route rather than treat coasting as a uniform deceleration.
Speed limits shape where power-off is useful. An approaching lower limit may provide an opportunity to coast down toward the permitted speed instead of maintaining power and braking later. The train must nevertheless be at or below the limit at the required location. Temporary restrictions and changes in permitted speed need to reach the control function in a form it can use.
Mass and resistance affect prediction. Passenger load, vehicle configuration, rolling resistance, aerodynamic drag and environmental conditions can alter the coast trajectory. An optimistic model may produce late braking interventions or repeated corrections; an overly conservative model may leave feasible savings unused. Evaluation should examine the range of conditions represented in the model and the response when measured behaviour differs from it.
Traffic and signalling can override the planned trajectory. A movement authority change, preceding train or altered stopping requirement may invalidate an energy-optimal plan. Repeated power-on and power-off corrections can erode the expected saving and may affect ride quality. Inspecting these transitions is often more revealing than reporting an average coasting percentage.
Distinguishing ATO optimization from safety enforcement
Energy optimization operates within the train control system’s permitted boundaries. The exact division of responsibility depends on the architecture: ATO may command normal driving, while a separate protection function supervises relevant limits and intervenes when required. A coast calculation must not be treated as a substitute for validated braking performance, movement authority supervision or other safety functions.
For a technical review, trace the interfaces among route data, train position and speed, ATO commands, braking control and the applicable protection system. Confirm how stale, unavailable or inconsistent inputs are detected and what operational response follows. Also examine whether a revised trajectory remains feasible after a delay or a restrictive authority is received. The correct fallback is architecture-specific and must be established in the system’s safety and operational documentation.
Standards and approval requirements depend on the railway, jurisdiction and system scope. A claim that a control strategy is energy-efficient does not by itself establish conformity or authorization for operation. Assess applicable requirements against the actual system boundary, including modifications to onboard software, trackside data and operating procedures.
Measuring whether coasting actually saves energy
Begin by defining the comparison. ATO can be assessed against an existing automatic profile, a representative manual-driving baseline or another authorized operating strategy. The baseline should use comparable routes, rolling stock, stops and service obligations. Comparing a slower ATO run with a faster reference run without accounting for the timetable difference can make an operational trade-off look like a pure efficiency gain.
Choose the electrical boundary before interpreting results:
- Traction energy delivered to the train: useful for observing propulsion demand, but it may exclude auxiliaries and network losses.
- Net onboard electrical energy: can account for energy drawn and returned, provided the meter and calculation distinguish their directions and treatment.
- Substation or network energy: captures a broader system effect, including interactions among trains, but requires suitable metering and attribution.
State whether regenerative energy is counted when generated, delivered to the supply or actually absorbed within the chosen boundary. These quantities need not be identical. Onboard metering alone may not show whether another train or the electrical infrastructure made productive use of energy returned to the line.
Record journey time, departure and arrival deviations, dwell time, train load where available, restrictions and traffic conditions alongside energy. Distance-normalized energy can help compare runs of different lengths, but it should not conceal differences in stops, gradients or service patterns. Report distributions and the number of valid observations as well as averages: an energy improvement concentrated in unusually quiet periods may not represent routine operation.
Use paired evidence, then investigate exceptions
In simulation, run the reference and proposed profiles against the same route, train parameters and operating constraints. Vary uncertain inputs such as mass, resistance and available running time to see whether the result is robust. Simulation is valuable for examining coast-point sensitivity, but its output depends on model fidelity, especially for braking, auxiliaries and electrical receptivity.
Operational trials add real disturbances and equipment behaviour. Where feasible, compare runs under closely matched conditions and review exclusions consistently. Synchronize energy measurements with position, speed and control-state logs so that changes can be attributed to the trajectory rather than a meter interval or unrelated event. Check instrumentation configuration and calibration before interpreting small differences.
When a predicted benefit does not appear, inspect a few representative traces. Late departures may have suppressed coasting; inaccurate gradients may have triggered corrective traction; a restriction may have moved braking earlier; or the meter boundary may include auxiliary consumption that masks a traction reduction. These explanations require verification in the data, not assumptions based on the aggregate result.
What a credible technical assessment should show
The strongest evidence links each claimed improvement to an observable change in operation: the train powered off at a feasible location, followed the permitted speed profile, met the relevant arrival and stopping requirements, and used less energy at a clearly defined boundary than the comparable reference. The assessment should also disclose conditions under which the controller reduces coasting, the uncertainty in measurements and models, and any effects on regenerative recovery or service resilience.
A high proportion of distance travelled with traction off is not itself the objective. The useful result is a repeatable reduction in appropriately measured energy without transferring the cost into lateness, unnecessary corrective acceleration, degraded operational margins or an unexamined safety assumption.
Article Categories
Latest Whitepapers
- 00
0000-00
California High-Speed Rail Authority Selects Siemens Mobility as Train ManufacturerPosted by: Marcus Track - 00
0000-00
How does ATO save train energy through coasting?Posted by: Marcus Track - 00
0000-00
US Space Force Predicts Swift Telescope's Uncontrolled Reentry After Rescue FailsPosted by: Dr. Julian Void
SYSTEM_ALERT_URGENT
Q3 SYMPOSIUM ON ORBITAL DYNAMICS
Registration for the Orbital Aerospace technical committee is now open. Node access required.
Recent Articles
![]() Nov 02, 2026California High-Speed Rail Authority Selects Siemens Mobility as Train ManufacturerCalifornia High-Speed Rail Authority Selects Siemens Mobility as Train Manufacturer
 Nov 02, 2026How does ATO save train energy through coasting?How does ATO save train energy through coasting?
![]() Nov 01, 2026US Space Force Predicts Swift Telescope's Uncontrolled Reentry After Rescue FailsUS Space Force Predicts Swift Telescope's Uncontrolled Reentry After Rescue Fails
 Nov 01, 2026How machine vision systems detect defects in composite airframesHow machine vision systems detect defects in composite airframes
![]() Oct 31, 2026AIA Releases 2027 Aerospace and Defense Trade PrioritiesAIA Releases 2027 Aerospace and Defense Trade Priorities
 Oct 31, 2026How to assess a rail safety standards consultant’s project experienceHow to assess a rail safety standards consultant’s project experience
![]() Oct 30, 2026FCC Proposes Updated Direct-to-Device Rules and Nearly 500 MHz of SpectrumFCC Proposes Updated Direct-to-Device Rules and Nearly 500 MHz of Spectrum
 Oct 30, 2026How does DO-178C support safety certification for avionics?How does DO-178C support safety certification for avionics?
![]() Oct 29, 2026Spain High-Speed Train Collision Kills at Least 68, Prompting Safety ReviewSpain High-Speed Train Collision Kills at Least 68, Prompting Safety Review
 Oct 29, 2026Which EN 15227 crash scenarios apply to high-speed rolling stock?Which EN 15227 crash scenarios apply to high-speed rolling stock?
![]() Oct 28, 2026GE Aerospace Releases Footage of World’s First High-Altitude Hybrid-Electric Flight TestGE Aerospace Releases Footage of World’s First High-Altitude Hybrid-Electric Flight Test
 Oct 28, 2026Is Global Aerospace & Advanced Transportation-Intelligence reliable for supplier research?Is Global Aerospace & Advanced Transportation-Intelligence reliable for supplier research?
![]() Oct 27, 2026FAA Certifies Boeing 737 MAX 10 After Years of DelaysFAA Certifies Boeing 737 MAX 10 After Years of Delays
 Oct 27, 2026Can an intermodal connectivity platform reduce rail handoff delays?Can an intermodal connectivity platform reduce rail handoff delays?
![]() Oct 26, 2026Chery Unveils Global Smart Mobility Strategy Targeting Robotaxis and eVTOLsChery Unveils Global Smart Mobility Strategy Targeting Robotaxis and eVTOLs
 Oct 26, 2026How to evaluate avionics for helicopters used in IFR operationsHow to evaluate avionics for helicopters used in IFR operations
![]() Oct 25, 2026Ukraine’s Defence Minister Says SpaceX Satellite Services Restored After Speed RestrictionsUkraine’s Defence Minister Says SpaceX Satellite Services Restored After Speed Restrictions
 Oct 25, 2026How satellite infrastructure for IoT affects sensor reporting delaysHow satellite infrastructure for IoT affects sensor reporting delays
![]() Oct 24, 2026China Successfully Launches Yaogan 50-03 SatelliteChina Successfully Launches Yaogan 50-03 Satellite
 Oct 24, 2026How gradients affect traction power needs in high-speed rolling stockHow gradients affect traction power needs in high-speed rolling stock
![]() Oct 23, 2026FAA Proposes Checks on Nearly 2,000 Boeing 737NGs Over Loss-of-Control RiskFAA Proposes Checks on Nearly 2,000 Boeing 737NGs Over Loss-of-Control Risk
 Oct 23, 2026How fuel choice affects specific impulse in liquid oxygen propulsionHow fuel choice affects specific impulse in liquid oxygen propulsion
![]() Oct 22, 2026QuantumScape Plans 100 MWh Solid-State Battery Line Targeting Aerospace and Other MarketsQuantumScape Plans 100 MWh Solid-State Battery Line Targeting Aerospace and Other Markets
 Oct 22, 2026How tank size limits hydrogen aircraft range on regional flightsHow tank size limits hydrogen aircraft range on regional flights
![]() Oct 21, 2026FAA Certifies Boeing 737-10, Clearing Regulatory Hurdle for DeliveriesFAA Certifies Boeing 737-10, Clearing Regulatory Hurdle for Deliveries
 Oct 21, 2026How are electric vertical takeoff aircraft certified in the US?How are electric vertical takeoff aircraft certified in the US?
![]() Oct 20, 2026Ohio Department of Transportation Releases Three-Year Advanced Air Mobility Action PlanOhio Department of Transportation Releases Three-Year Advanced Air Mobility Action Plan
 Oct 20, 2026How does magnetic flux density in tesla affect maglev lift force?How does magnetic flux density in tesla affect maglev lift force?
![]() Oct 19, 2026ZeroAvia Completes Key Ground Tests of ZA600 Hydrogen Fuel Cell PowertrainZeroAvia Completes Key Ground Tests of ZA600 Hydrogen Fuel Cell Powertrain
 Oct 19, 2026How spacecraft integration affects advanced propulsion costsHow spacecraft integration affects advanced propulsion costs
 Oct 18, 2026How chilldown prevents cavitation in cryogenic engine systemsHow chilldown prevents cavitation in cryogenic engine systems
 Oct 17, 2026How explainability affects algorithmic trust in AI flight systemsHow explainability affects algorithmic trust in AI flight systems
 Oct 16, 2026How to evaluate transportation technology for Middle East heatHow to evaluate transportation technology for Middle East heat
 Oct 15, 2026How common-cause failures defeat redundancy logic in European avionicsHow common-cause failures defeat redundancy logic in European avionics
 Oct 14, 2026How DO-160 applies to aerospace technology testing for avionicsHow DO-160 applies to aerospace technology testing for avionics